bundles / scipy 2.0.0.dev0+git20260907.41eeb59 / scipy / signal / _signaltools / lfilter
function
scipy.signal._signaltools:lfilter
source: build-install/usr/lib/python3.14/site-packages/scipy/signal/_signaltools.py:2099
Signature
def lfilter(b, a, x, axis = -1, zi = None)Summary
Filter data along one-dimension with an IIR or FIR filter.
Extended Summary
Filter a data sequence, x, using a digital filter. This works for many fundamental data types (including Object type). The filter is a direct form II transposed implementation of the standard difference equation (see Notes).
The function sosfilt (and filter design using output='sos') should be preferred over lfilter for most filtering tasks, as second-order sections have fewer numerical problems.
Parameters
b: array_likeThe numerator coefficient vector in a 1-D sequence.
a: array_likeThe denominator coefficient vector in a 1-D sequence. If
a[0]is not 1, then bothaandbare normalized bya[0].x: array_likeAn N-dimensional input array.
axis: int, optionalThe axis of the input data array along which to apply the linear filter. The filter is applied to each subarray along this axis. Default is -1.
zi: array_like, optionalInitial conditions for the filter delays. It is a vector (or array of vectors for an N-dimensional input) of length
max(len(a), len(b)) - 1. Ifziis None or is not given then initial rest is assumed. See lfiltic for more information.
Returns
y: arrayThe output of the digital filter.
zf: array, optionalIf
ziis None, this is not returned, otherwise, zf holds the final filter delay values.
Notes
The filter function is implemented as a direct II transposed structure. This means that the filter implements
a[0]*y[n] = b[0]*x[n] + b[1]*x[n-1] + ... + b[M]*x[n-M]
                      - a[1]*y[n-1] - ... - a[N]*y[n-N]
where M is the degree of the numerator, N is the degree of the denominator, and n is the sample number. It is implemented using the following difference equations (assuming M = N)
a[0]*y[n] = b[0] * x[n]               + d[0][n-1]
  d[0][n] = b[1] * x[n] - a[1] * y[n] + d[1][n-1]
  d[1][n] = b[2] * x[n] - a[2] * y[n] + d[2][n-1]
...
d[N-2][n] = b[N-1]*x[n] - a[N-1]*y[n] + d[N-1][n-1]
d[N-1][n] = b[N] * x[n] - a[N] * y[n]
where d are the state variables.
The rational transfer function describing this filter in the z-transform domain is
                    -1              -M
        b[0] + b[1]z  + ... + b[M] z
Y(z) = -------------------------------- X(z)
                    -1              -N
        a[0] + a[1]z  + ... + a[N] z
Examples
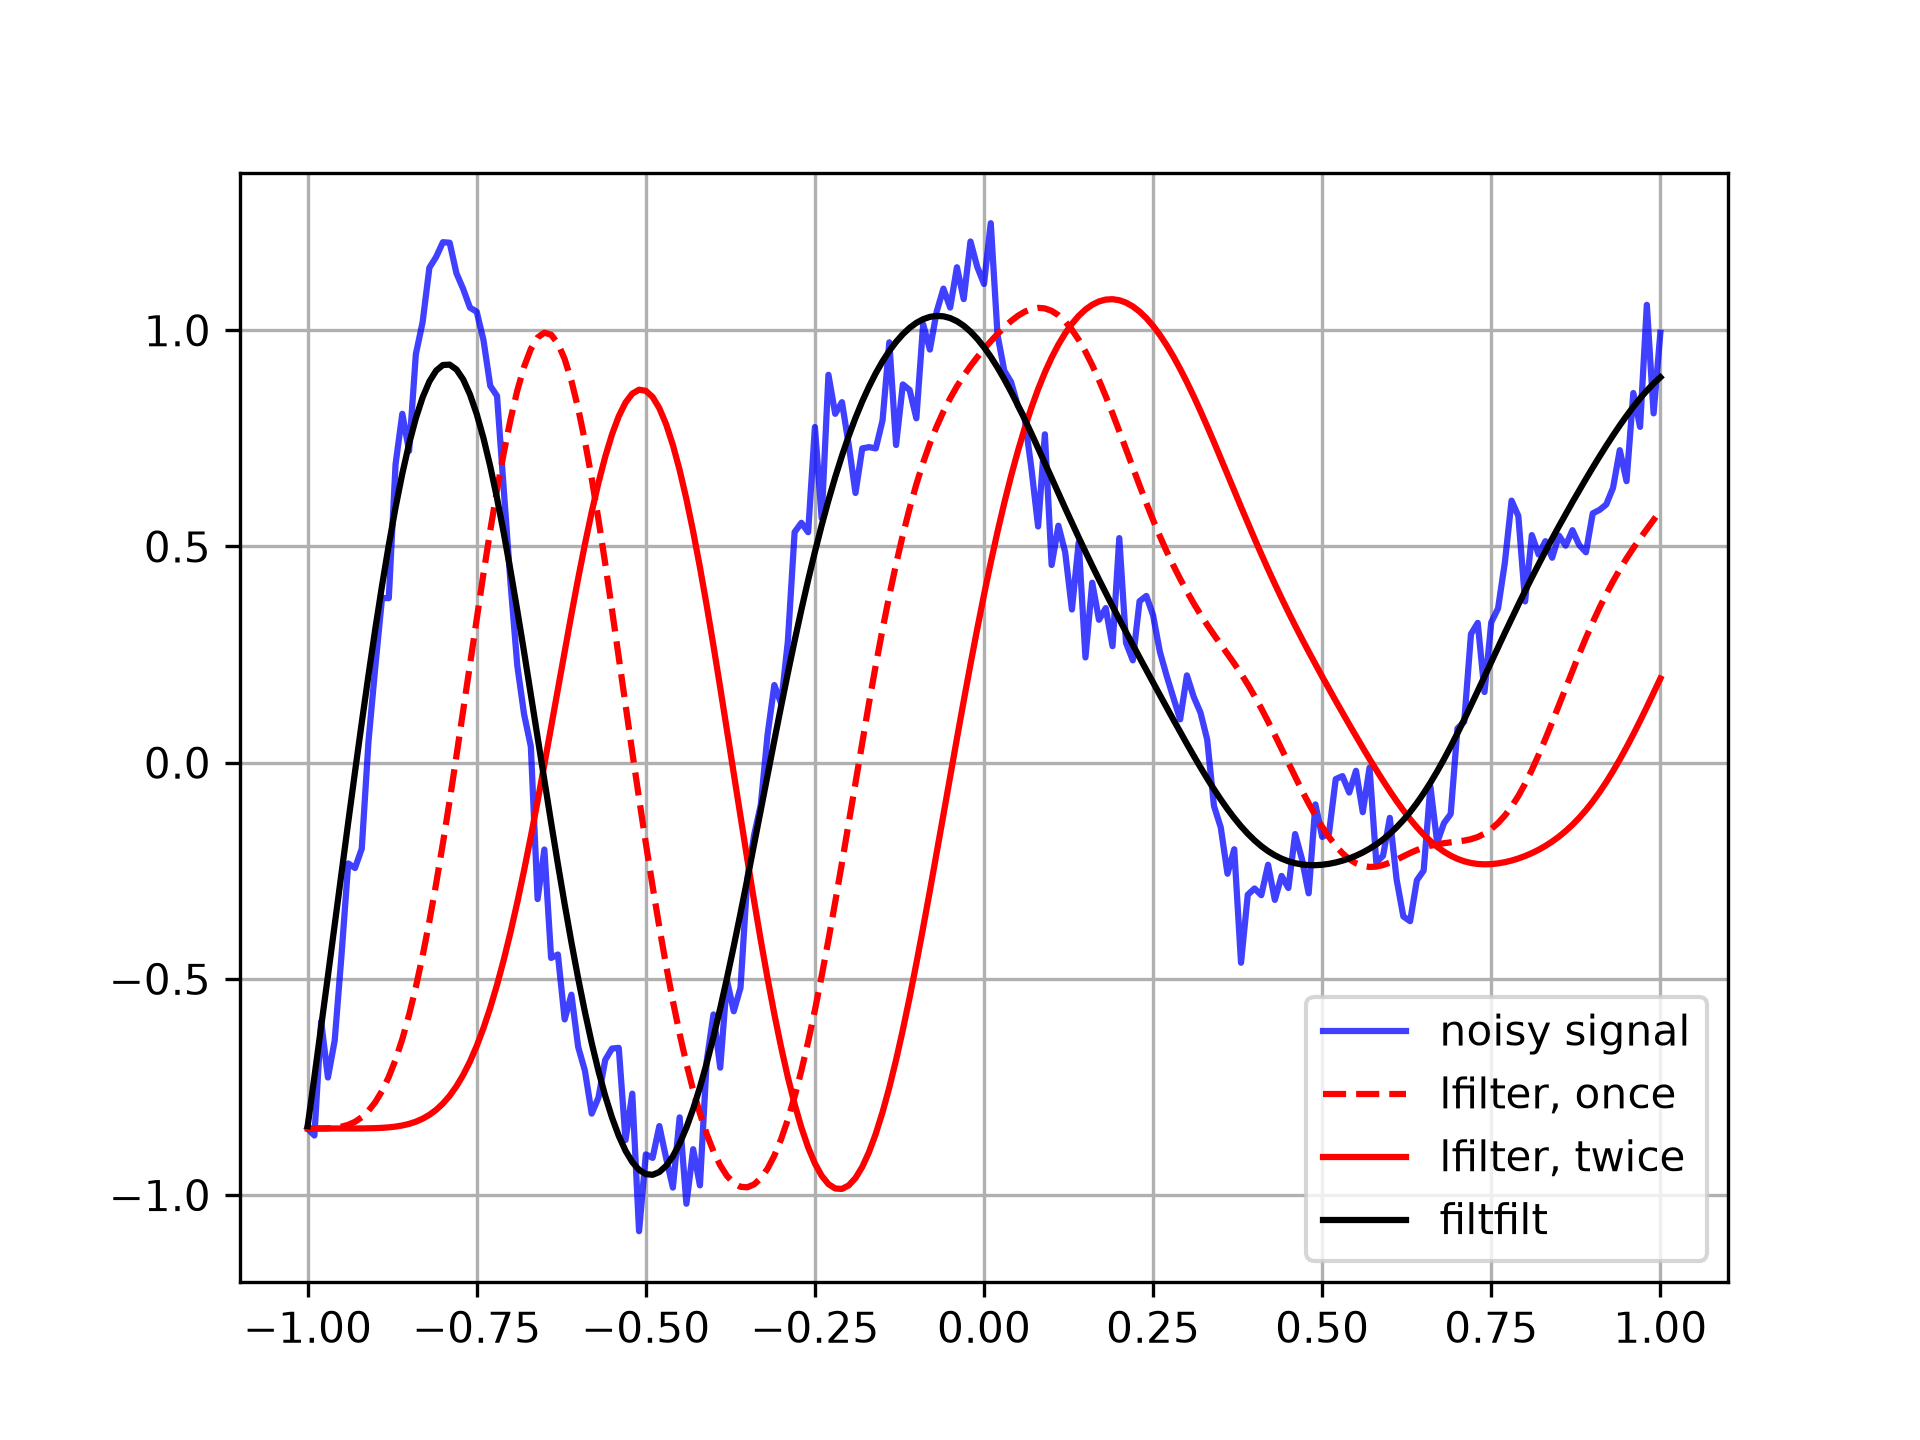
Generate a noisy signal to be filtered:import numpy as np from scipy import signal import matplotlib.pyplot as plt rng = np.random.default_rng() t = np.linspace(-1, 1, 201) x = (np.sin(2*np.pi*0.75*t*(1-t) + 2.1) + 0.1*np.sin(2*np.pi*1.25*t + 1) + 0.18*np.cos(2*np.pi*3.85*t)) xn = x + rng.standard_normal(len(t)) * 0.08✓
b, a = signal.butter(3, 0.05)
✓zi = signal.lfilter_zi(b, a) z, _ = signal.lfilter(b, a, xn, zi=zi*xn[0])✓
z2, _ = signal.lfilter(b, a, z, zi=zi*z[0])
✓y = signal.filtfilt(b, a, xn)
✓plt.figure plt.plot(t, xn, 'b', alpha=0.75) plt.plot(t, z, 'r--', t, z2, 'r', t, y, 'k') plt.legend(('noisy signal', 'lfilter, once', 'lfilter, twice', 'filtfilt'), loc='best')✗
<matplotlib.legend.Legend object at 0x7f3f6820b0e0>
plt.grid(True)
plt.show()
✓
See also
- filtfilt
A forward-backward filter, to obtain a filter with zero phase.
- lfilter_zi
Compute initial state (steady state of step response) for
lfilter.- lfiltic
Construct initial conditions for
lfilter.- savgol_filter
A Savitzky-Golay filter.
- sosfilt
Filter data using cascaded second-order sections.
- sosfiltfilt
A forward-backward filter using second-order sections.
Aliases
scipy.signal.lfilter